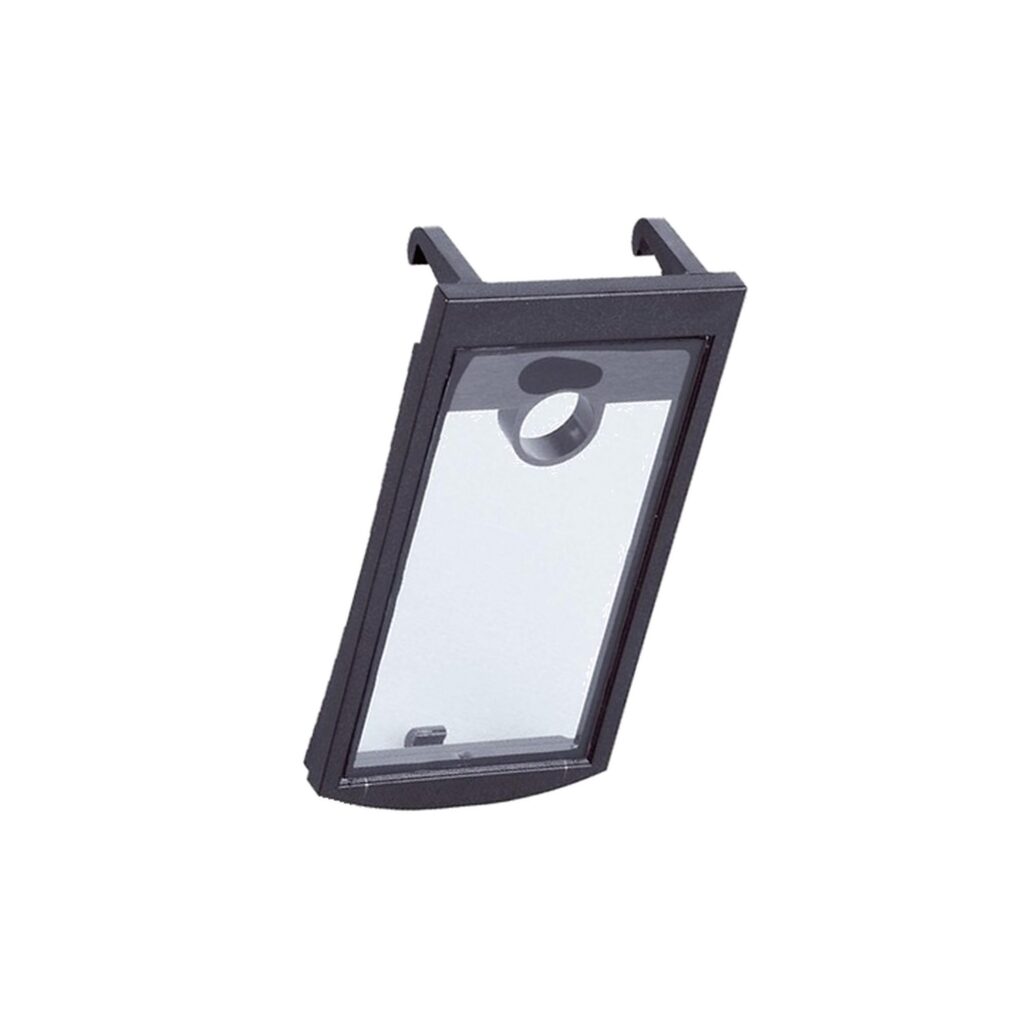
KUP-0610-S | SICK 6/10 mm Bar Coupling Encoder
Introduction:
SICK KUP-0610-S bar shaft coupling with 6 mm and 10 mm bores, 0.8 N·m torque and ±0.3 mm offset tolerance for dependable encoder-to-shaft connection.
 Customer Reviews
UBEST Automation – Trusted Global Automation Parts Supplier
We offer a wide range of in-stock industrial automation spare parts. All products come with a 12-month warranty and a 30-day refund for quality issues.
Product Attributes:
Notice: For real-time prices and inventory, please click the button below to contact us.
What the SICK KUP-0610-S Bar Coupling Does
The SICK KUP-0610-S is a bar (beam) shaft coupling for encoders with a 6 mm bore on the encoder side and a 10 mm bore on the drive side. It carries a maximum torque of 0.8 N·m and tolerates up to ±0.3 mm of axial and radial shaft offset, making it a rugged interface for mission-critical motion feedback in demanding environments.
In oil and gas machinery, small misalignments between an encoder shaft and a driven shaft can shorten component life. This coupling absorbs those offsets while transmitting rotation up to 10,000 rpm, so the encoder stays isolated from vibration and shaft wander.
Key Specifications of This unit Encoder Coupling
- Bore diameter, encoder side (D1): 6 mm
- Bore diameter, drive side (D2): 10 mm
- Coupling type: Bar coupling
- Material: Glass-fiber-reinforced polyamide with aluminum hub
- Maximum torque: 0.8 N·m (80 Ncm per datasheet)
- Maximum speed: 10,000 rpm
- Axial offset compensation: ±0.3 mm maximum
- Radial offset compensation: ±0.3 mm maximum
- Angular offset compensation: ±3° maximum
- Operating temperature: –10 °C to +80 °C per datasheet
- Overall length: ~24 mm (S family); outer diameter not available in datasheet
The glass-fiber-reinforced polyamide body keeps the coupling light and electrically insulating, while the aluminum hub provides a solid clamp area. Because the bar design flexes rather than slides, it compensates for offset without adding significant restoring force. Note that clamping screw details are not available in the datasheet; confirm fastening hardware with the supplier.
How This unit Handles Misalignment and Temperature
Bar couplings are often chosen when shafts cannot be perfectly aligned. This unit compensates for ±0.3 mm radial and ±0.3 mm axial offset, plus ±3° angular misalignment. Consequently, installers can mount an encoder without precision shimming, which reduces commissioning time on skids and packaged equipment.
Operating temperature is rated from –10 °C to +80 °C per the datasheet. In oil and gas service, that range covers most sheltered and climate-controlled enclosures. However, verify the ambient temperature at the encoder location, especially near heat exchangers or engine-driven pumps. Because the coupling is an accessory, it should be matched to the encoder's own temperature rating.
Where This unit Fits in Oil and Gas Equipment
This coupling connects an encoder to a rotating shaft on valve actuators, metering pumps, and small gearboxes. In upstream applications, it can link a feedback encoder to a choke manifold actuator. Midstream, it suits pipeline valve position feedback where vibration is present. Downstream, it supports pump stroke or fan speed monitoring.
Because the coupling absorbs offset, it reduces side loads on encoder bearings. That matters in mission-critical loops where a failed feedback signal can trip a process. This unit is built for demanding environments, and its polyamide-aluminum construction resists typical industrial contaminants.
unit Compared with Other Encoder Coupling Types
Buyers often compare bar couplings with bellows, disc, and jaw couplings. The bullet list below highlights practical differences based on the available data for This unit.
- Bar coupling (unit): 6 mm / 10 mm bores, 0.8 N·m, ±0.3 mm radial and axial offset, ±3° angular, 10,000 rpm, –10 °C to +80 °C.
- Bellows coupling: typically higher torque and zero backlash, but often stiffer and less tolerant of parallel offset; exact ratings vary by model.
- Disc coupling: good for high speed and torque, yet usually requires precise alignment and may cost more.
- Jaw coupling: simple and replaceable spider, but can introduce backlash and may not suit high-resolution encoder feedback.
For a 6 mm encoder shaft and a 10 mm drive shaft with moderate misalignment, This unit offers a balanced, field-proven solution. If your application demands higher torque or different bore sizes, consult the supplier for alternatives.
Installation and Maintenance Guidance
Install the coupling by sliding the 6 mm bore onto the encoder shaft and the 10 mm bore onto the drive shaft. Align the shafts as closely as practical, then allow the coupling to compensate for residual offset within its ±0.3 mm and ±3° limits. Tighten the clamping screws evenly; however, since fastening details are not available in the datasheet, confirm the correct screw size and torque with PetroPartsOnline.
During routine maintenance, inspect the coupling for cracks, wear, or loose hubs. Because the polyamide body can age under sustained heat, check it more often in hot locations. Also verify that shaft offset has not increased due to bearing wear. Replacing a worn coupling early protects the encoder and avoids unplanned downtime. For critical operations, keep a spare on hand.
Frequently Asked Questions
What is the maximum speed of the SICK unit?
The SICK unit is rated for a maximum speed of 10,000 rpm. Confirm that the connected encoder and drive shaft also support this speed.
Does This unit work as a servo motor replacement coupling?
This unit is an encoder coupling, not a servo motor. However, its 6 mm and 10 mm bores and 0.8 N·m torque may suit small servo feedback shafts. Verify shaft diameters and torque requirements before selecting it for servo motor replacement.
What is the operating temperature range of this coupling?
Per the datasheet, the SICK unit operates from –10 °C to +80 °C. Ensure the ambient temperature at the installation point stays within this range.
Can This unit replace a failed coupling in a VFD-driven system?
Yes, if the shaft sizes and torque match. The coupling can serve as a vfd parts replacement on encoder feedback shafts. Check that the VFD-controlled motor does not exceed 10,000 rpm at the coupling.
What is the torque capacity of This unit?
The SICK unit has a maximum torque capacity of 0.8 N·m (80 Ncm per datasheet). Do not exceed this value in continuous operation.
Contact PetroPartsOnline for parts suited to your application's requirements.
{"@context": "https://schema.org", "@graph": [{"@type": "Product", "name": "KUP-0610-S | SICK 6/10 mm Bar Coupling Encoder", "mpn": "KUP-0610-S", "sku": "KUP-0610-S", "brand": {"@type": "Brand", "name": "SICK"}, "description": "What the SICK KUP-0610-S Bar Coupling Does The SICK KUP-0610-S is a bar (beam) shaft coupling for encoders with a 6 mm bore on the encoder side and a 10 mm bore on the drive side. It carries a maximum torque of 0.8 N·m and tolerates up to ±0.3 mm of axial and radial shaft offset, making it a rugged interface for mission-critical motion feedback in demanding environments. In oil and gas machinery, small misalignments between an encoder shaft and a driven shaft can shorten component life. This cou", "image": ["https://www.petropartsonline.com/wp-content/uploads/2026/10/1793130221-api_image__fp73834391.jpg", "https://www.petropartsonline.com/wp-content/uploads/2026/10/1793130230-api_image__fpa265bc72.jpg", "https://www.petropartsonline.com/wp-content/uploads/2026/10/1793130238-api_image__fpa311e196.jpg"]}, {"@type": "FAQPage", "mainEntity": [{"@type": "Question", "name": "What is the maximum speed of the SICK unit?", "acceptedAnswer": {"@type": "Answer", "text": "The SICK unit is rated for a maximum speed of 10,000 rpm. Confirm that the connected encoder and drive shaft also support this speed."}}, {"@type": "Question", "name": "Does This unit work as a servo motor replacement coupling?", "acceptedAnswer": {"@type": "Answer", "text": "This unit is an encoder coupling, not a servo motor. However, its 6 mm and 10 mm bores and 0.8 N·m torque may suit small servo feedback shafts. Verify shaft diameters and torque requirements before selecting it for servo motor replacement."}}, {"@type": "Question", "name": "What is the operating temperature range of this coupling?", "acceptedAnswer": {"@type": "Answer", "text": "Per the datasheet, the SICK unit operates from –10 °C to +80 °C. Ensure the ambient temperature at the installation point stays within this range."}}, {"@type": "Question", "name": "Can This unit replace a failed coupling in a VFD-driven system?", "acceptedAnswer": {"@type": "Answer", "text": "Yes, if the shaft sizes and torque match. The coupling can serve as a vfd parts replacement on encoder feedback shafts. Check that the VFD-controlled motor does not exceed 10,000 rpm at the coupling."}}, {"@type": "Question", "name": "What is the torque capacity of This unit?", "acceptedAnswer": {"@type": "Answer", "text": "The SICK unit has a maximum torque capacity of 0.8 N·m (80 Ncm per datasheet). Do not exceed this value in continuous operation. Contact PetroPartsOnline for parts suited to your application's requirements."}}]}]}